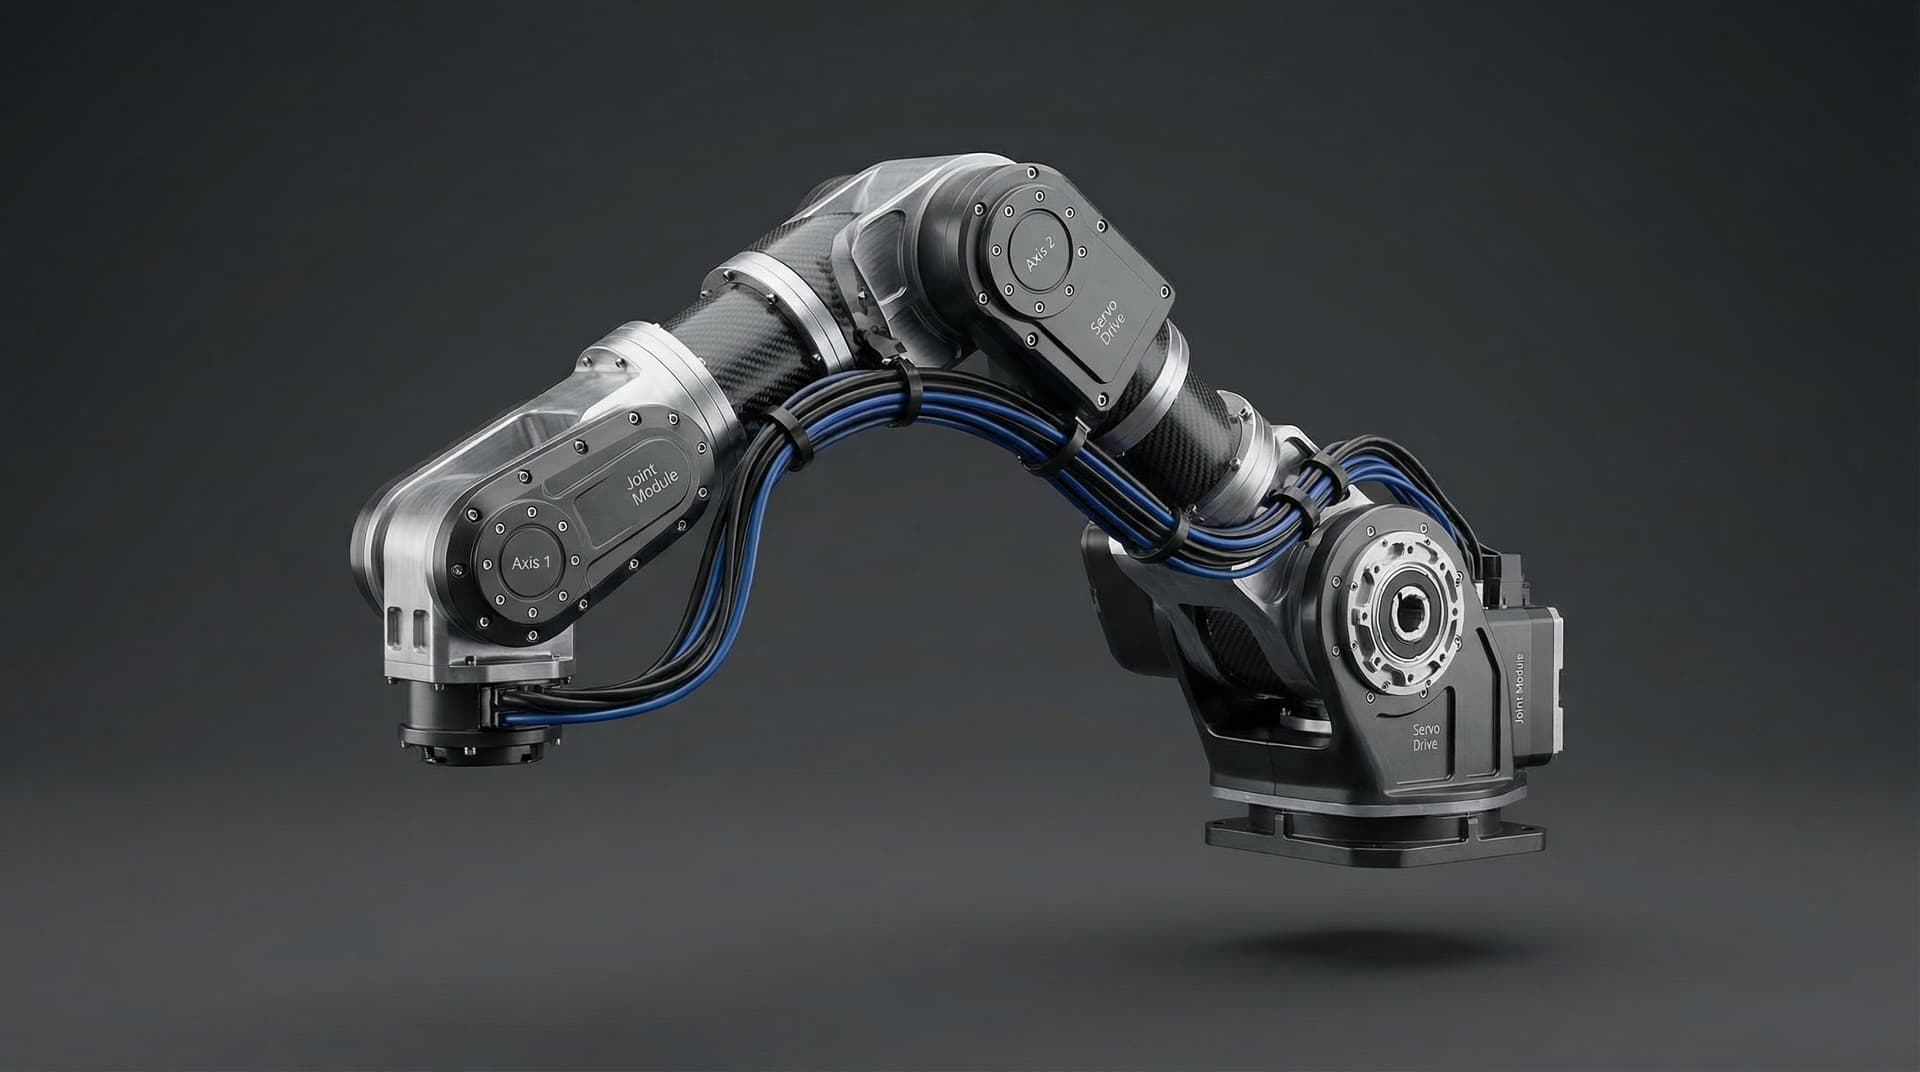
6-DOF Teleoperated Robotic Arm Mechanical Architecture & Kinematics
Mechanical architecture, cycloidal joint packaging, kinematic clearance checking, and machining DFM for a compact 6-DOF teleoperated manipulator arm.
Detailed engineering breakdowns covering the problem, approach, technical decisions, validation and outputs behind selected YantriX work.
Technical proof
Explore how we approach mechanical packaging, kinematic mechanisms, finite element validation, ROS 2 autonomous navigation, and physical additive manufacturing.

Mechanical architecture, cycloidal joint packaging, kinematic clearance checking, and machining DFM for a compact 6-DOF teleoperated manipulator arm.

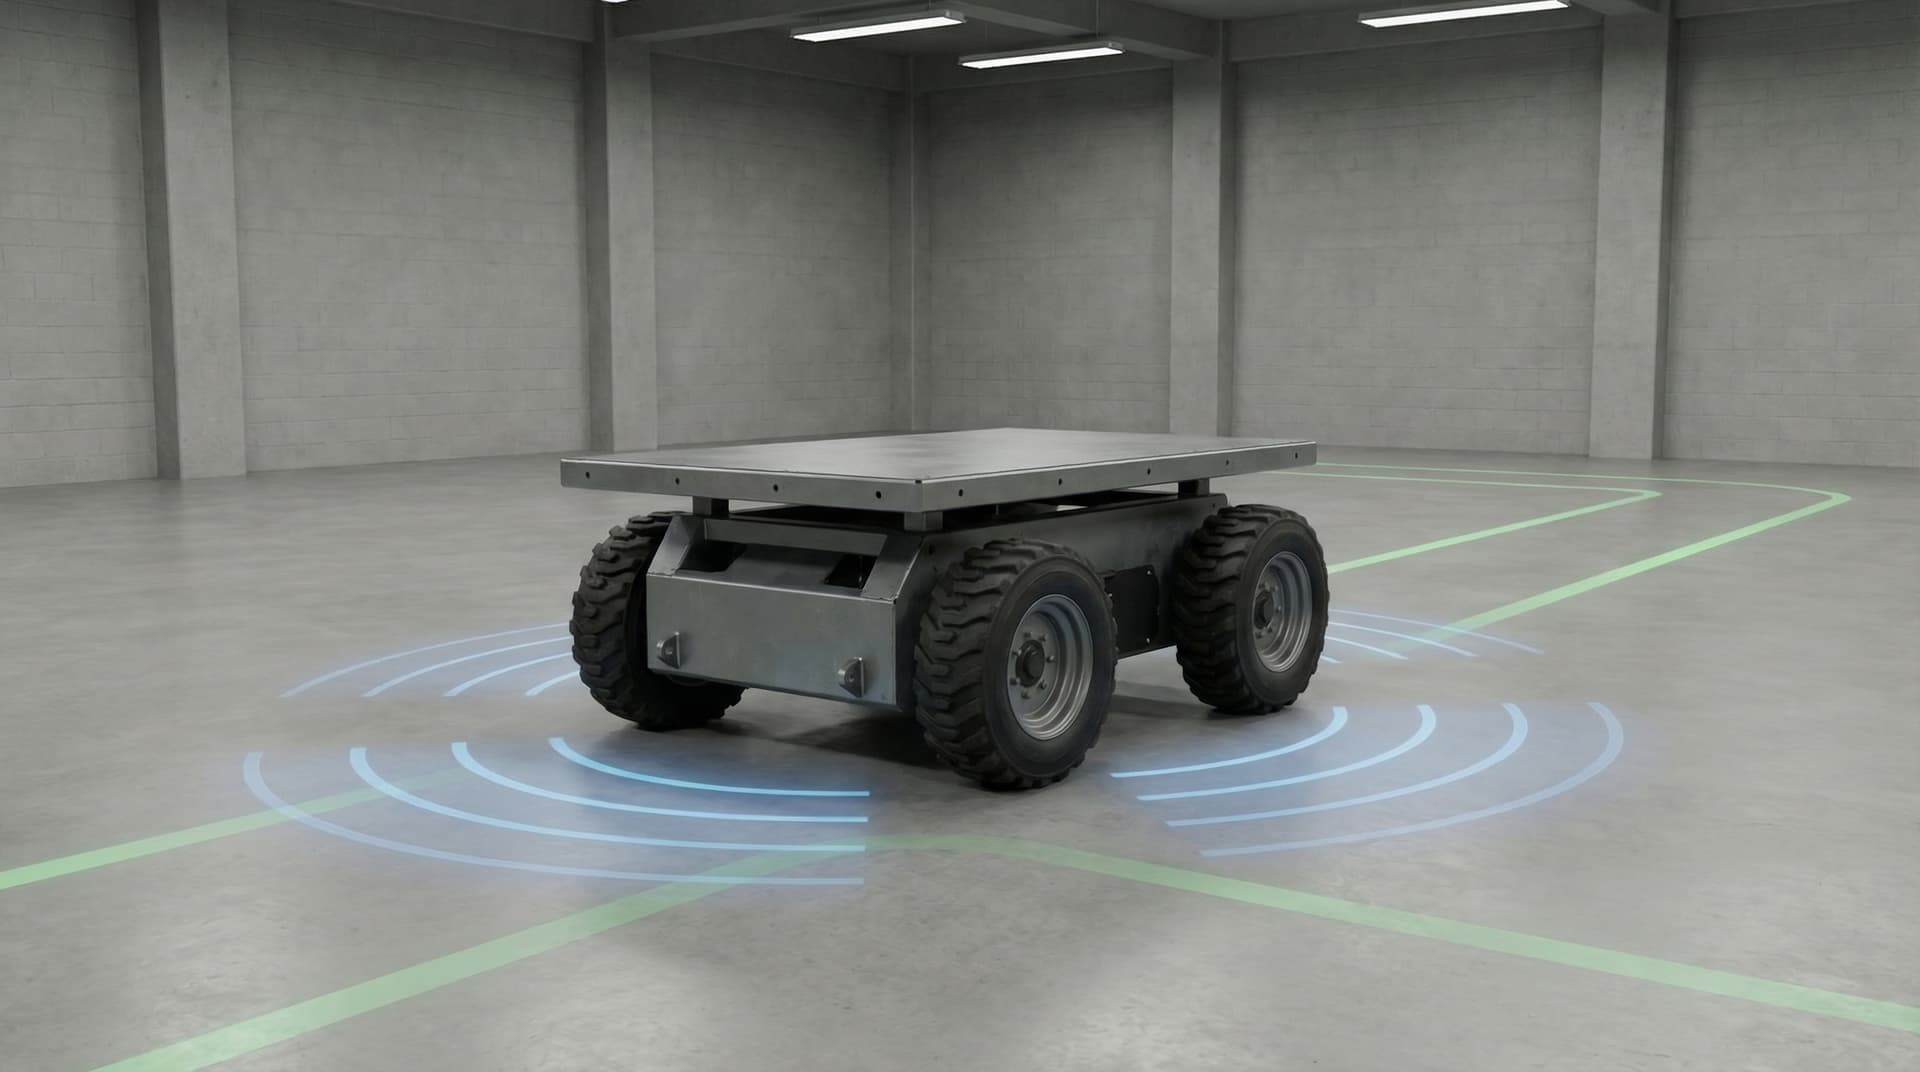
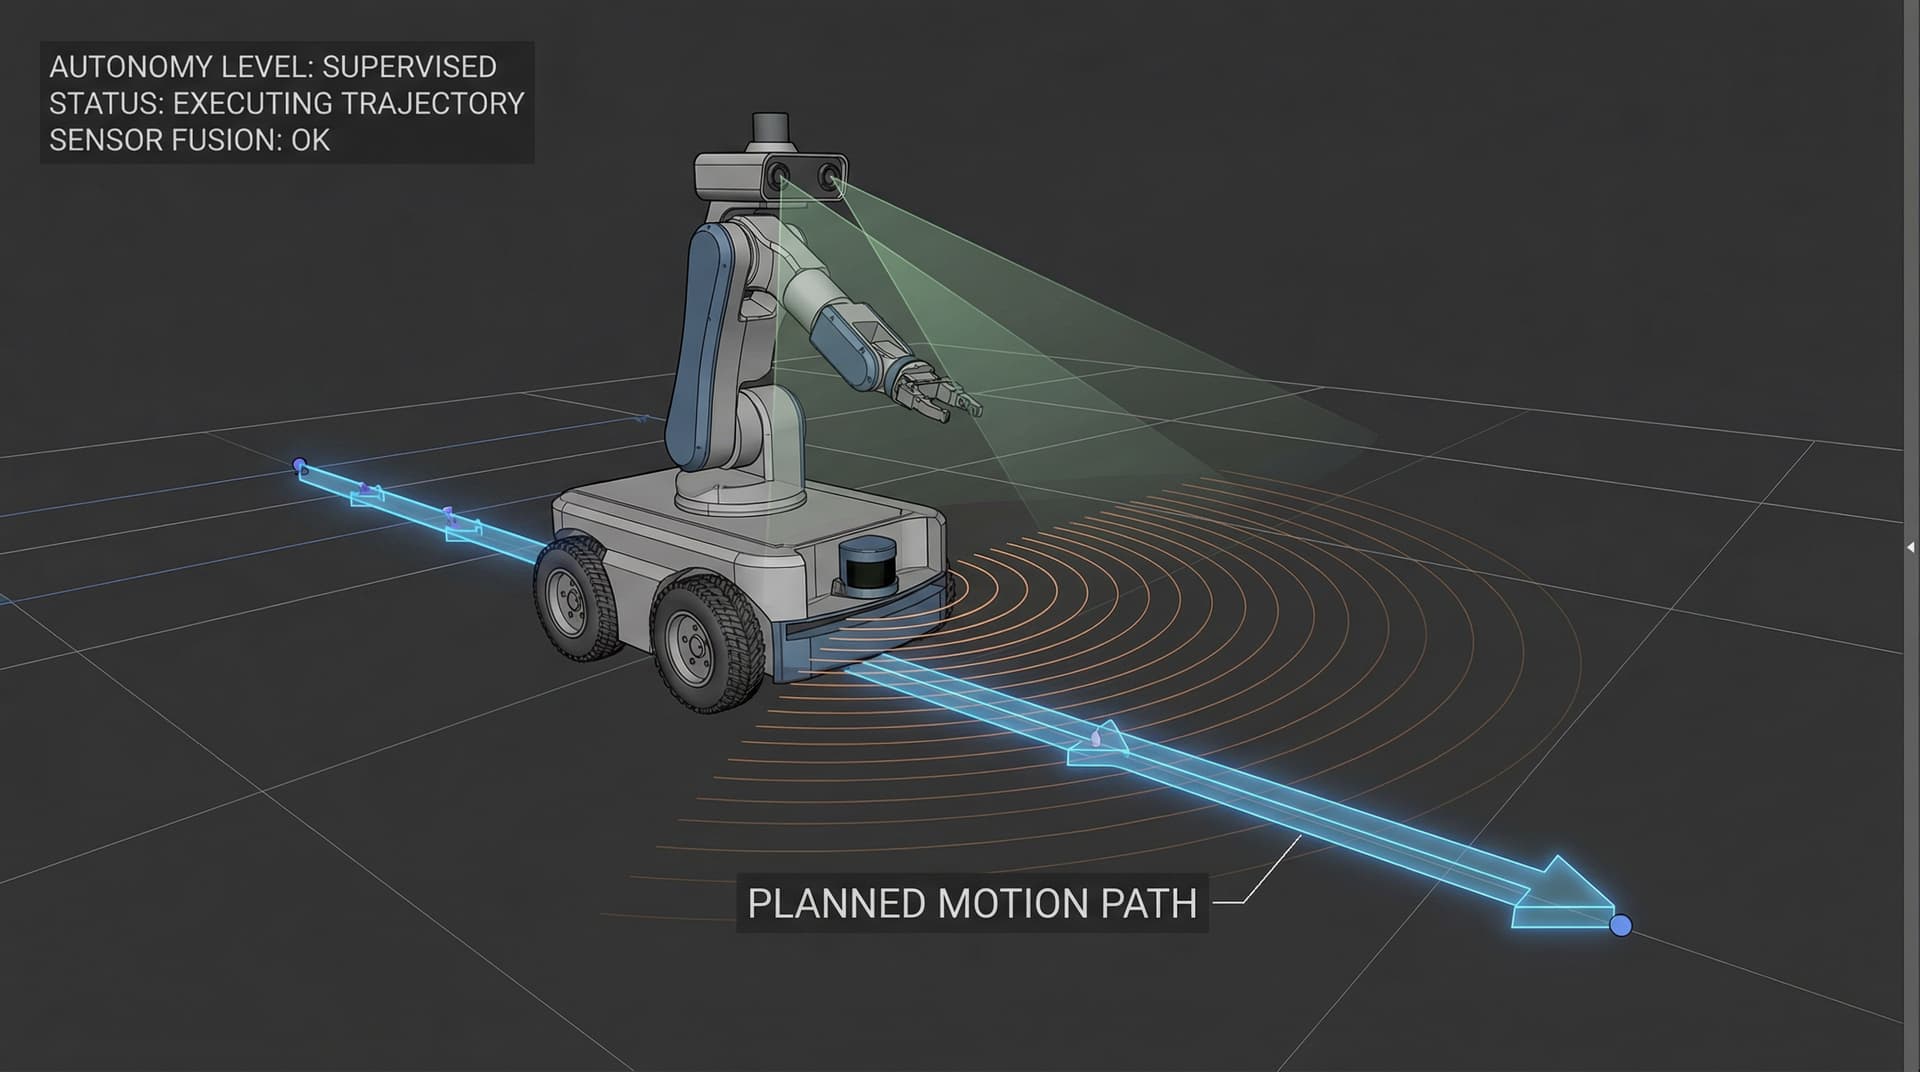
In-house engineering development of an 80 kg payload AMR platform—custom skid-steer steel chassis, ROS 2 Humble Nav2 autonomy, LiDAR SLAM, and embedded motor control.

In-house functional prototyping program evaluating joint stiffness, heat-set brass insert installation, and TPU compliant seals for a robotic actuator housing using engineering polymers.

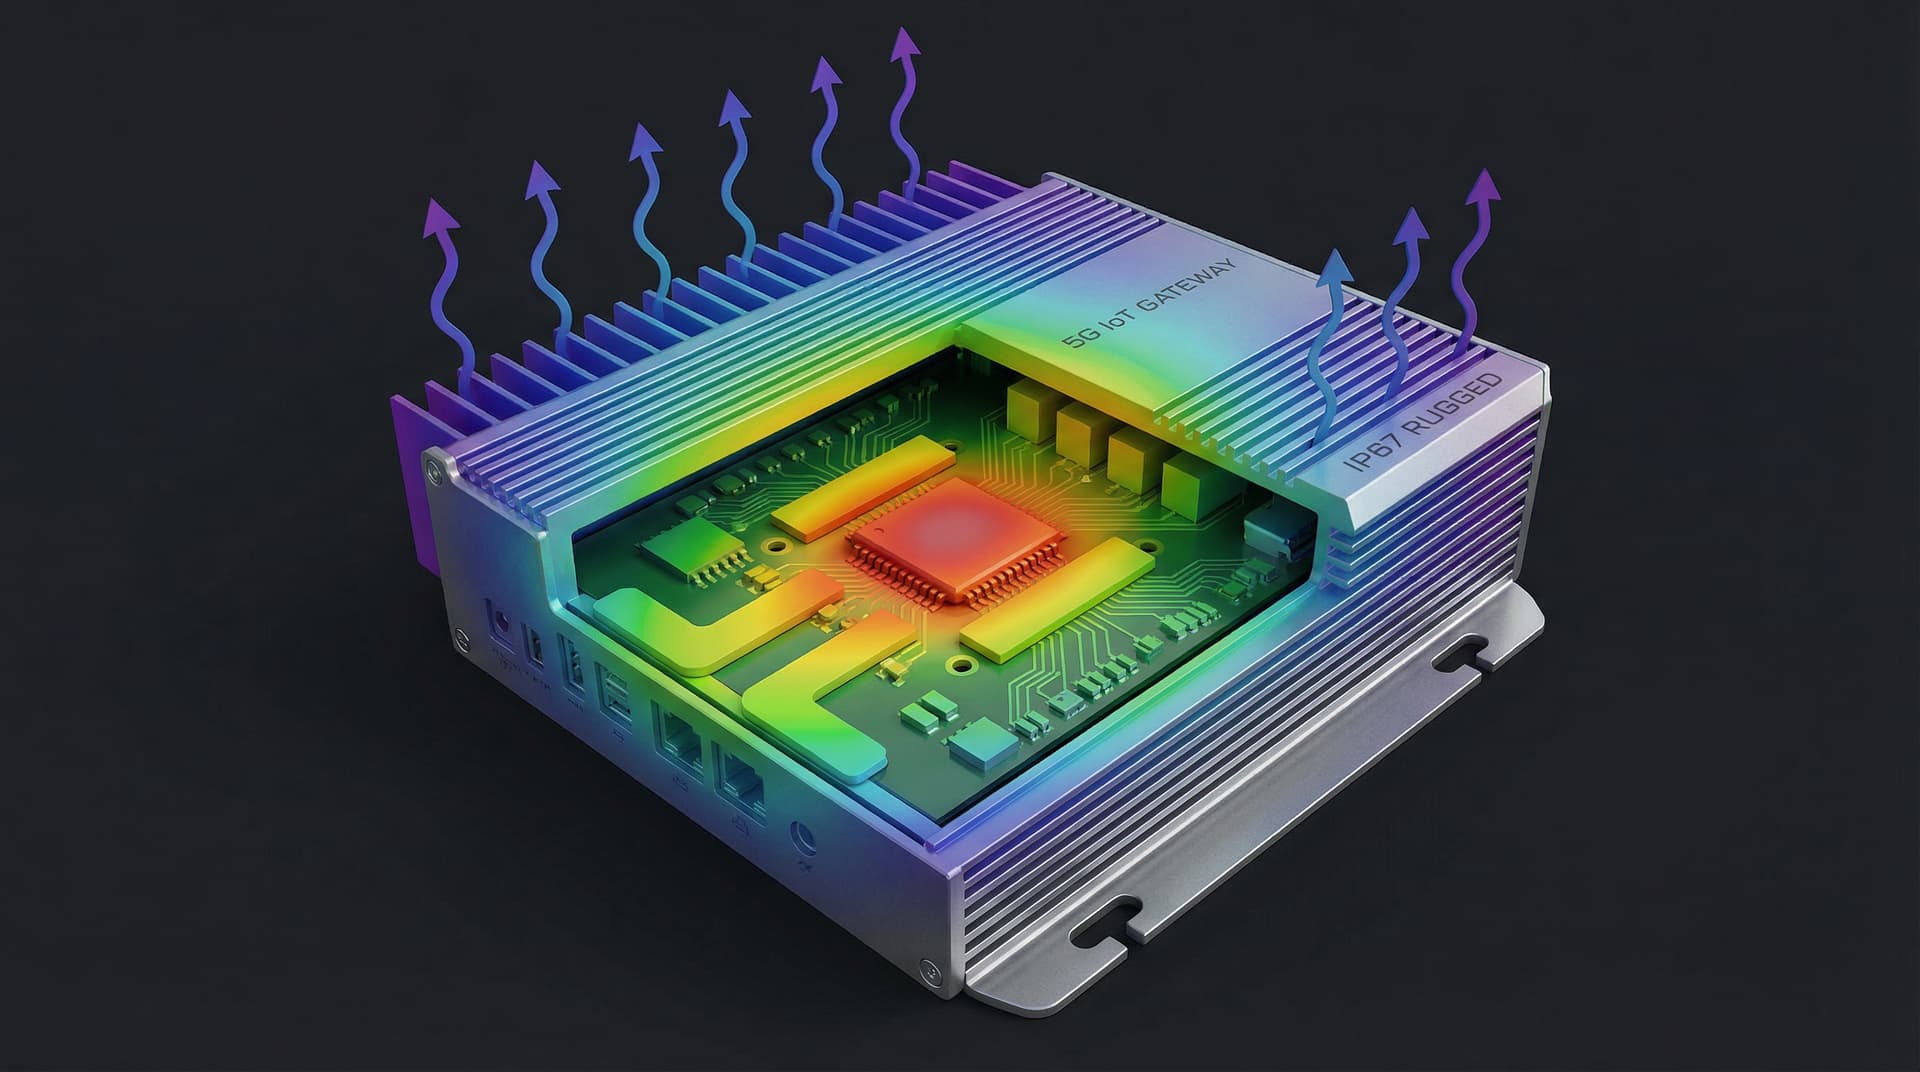
Engineering design study examining DFM architecture, mold draft angles, wall thickness uniformity, and silicone gasket retention for an outdoor IP67 IoT gateway enclosure.

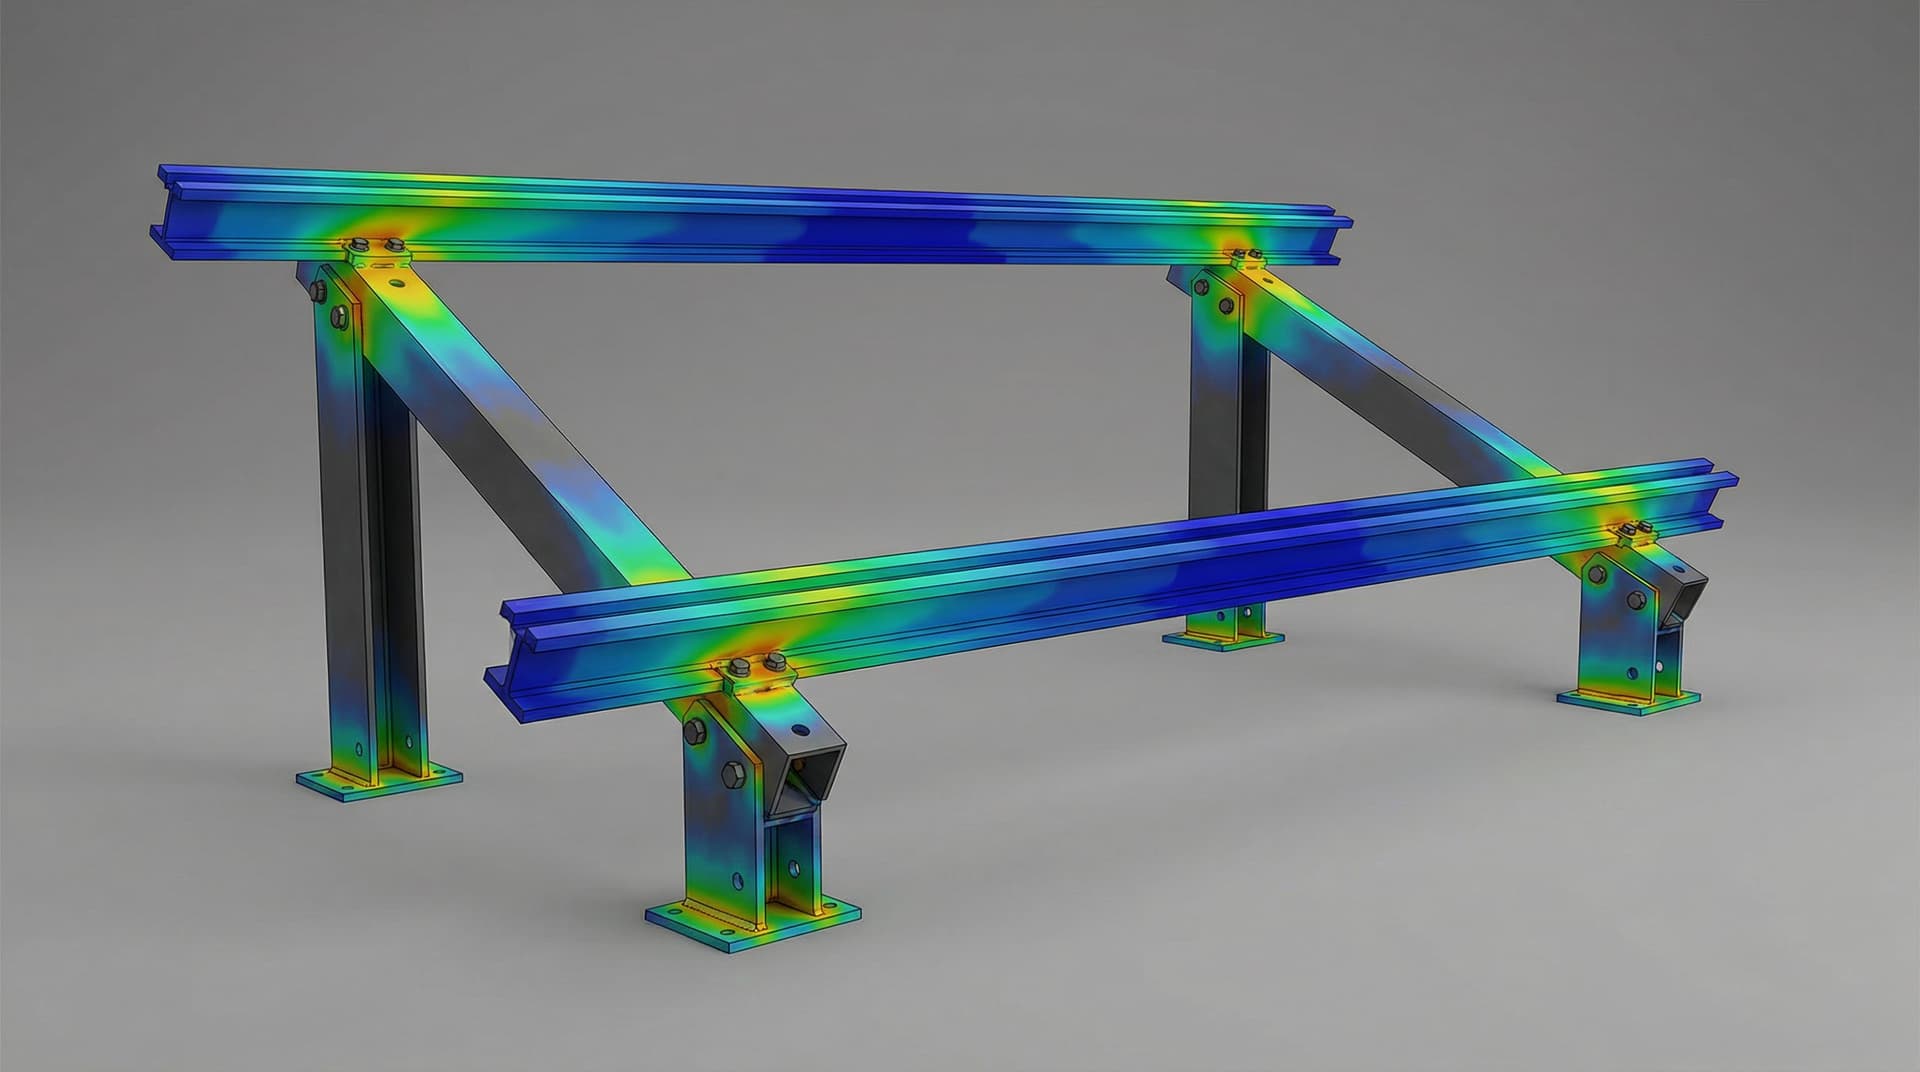
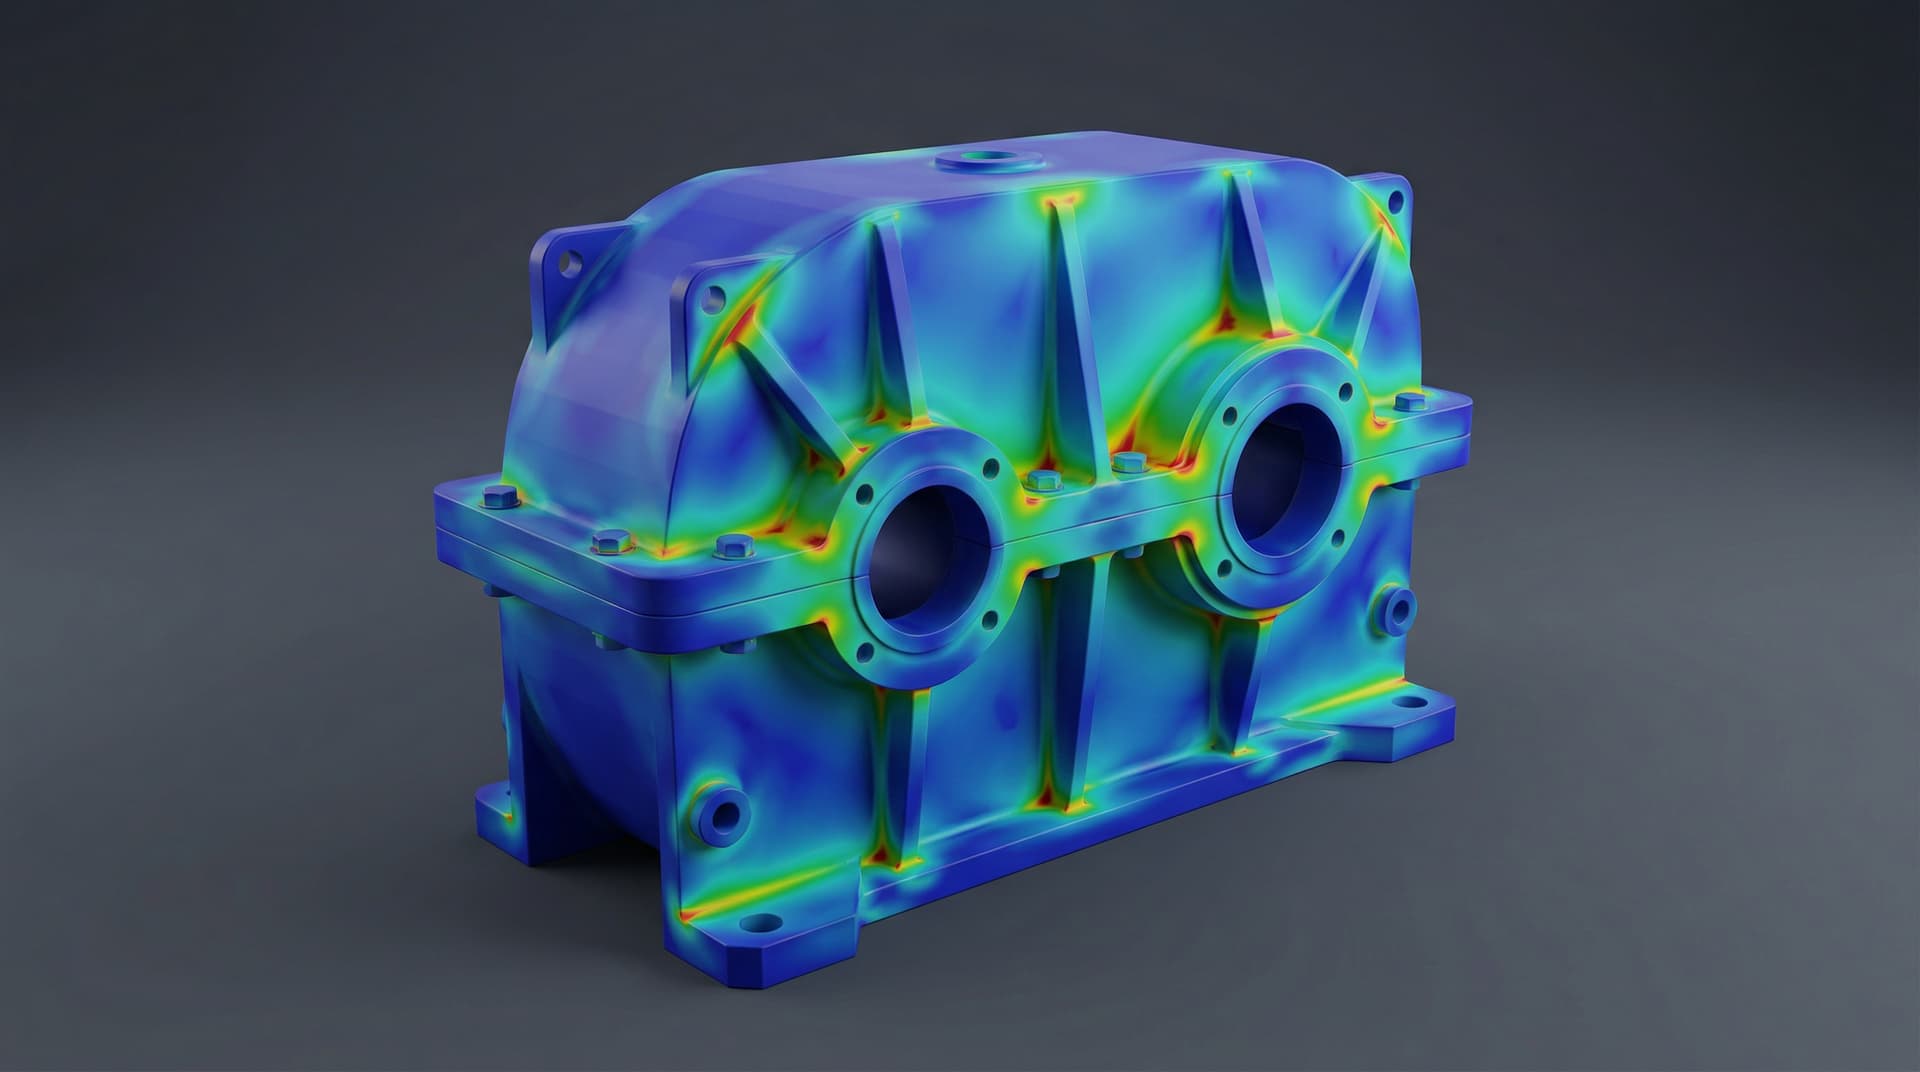
Structural engineering study evaluating stress concentrations, deflection, and material optimization on heavy-duty industrial mounting brackets using finite element analysis.

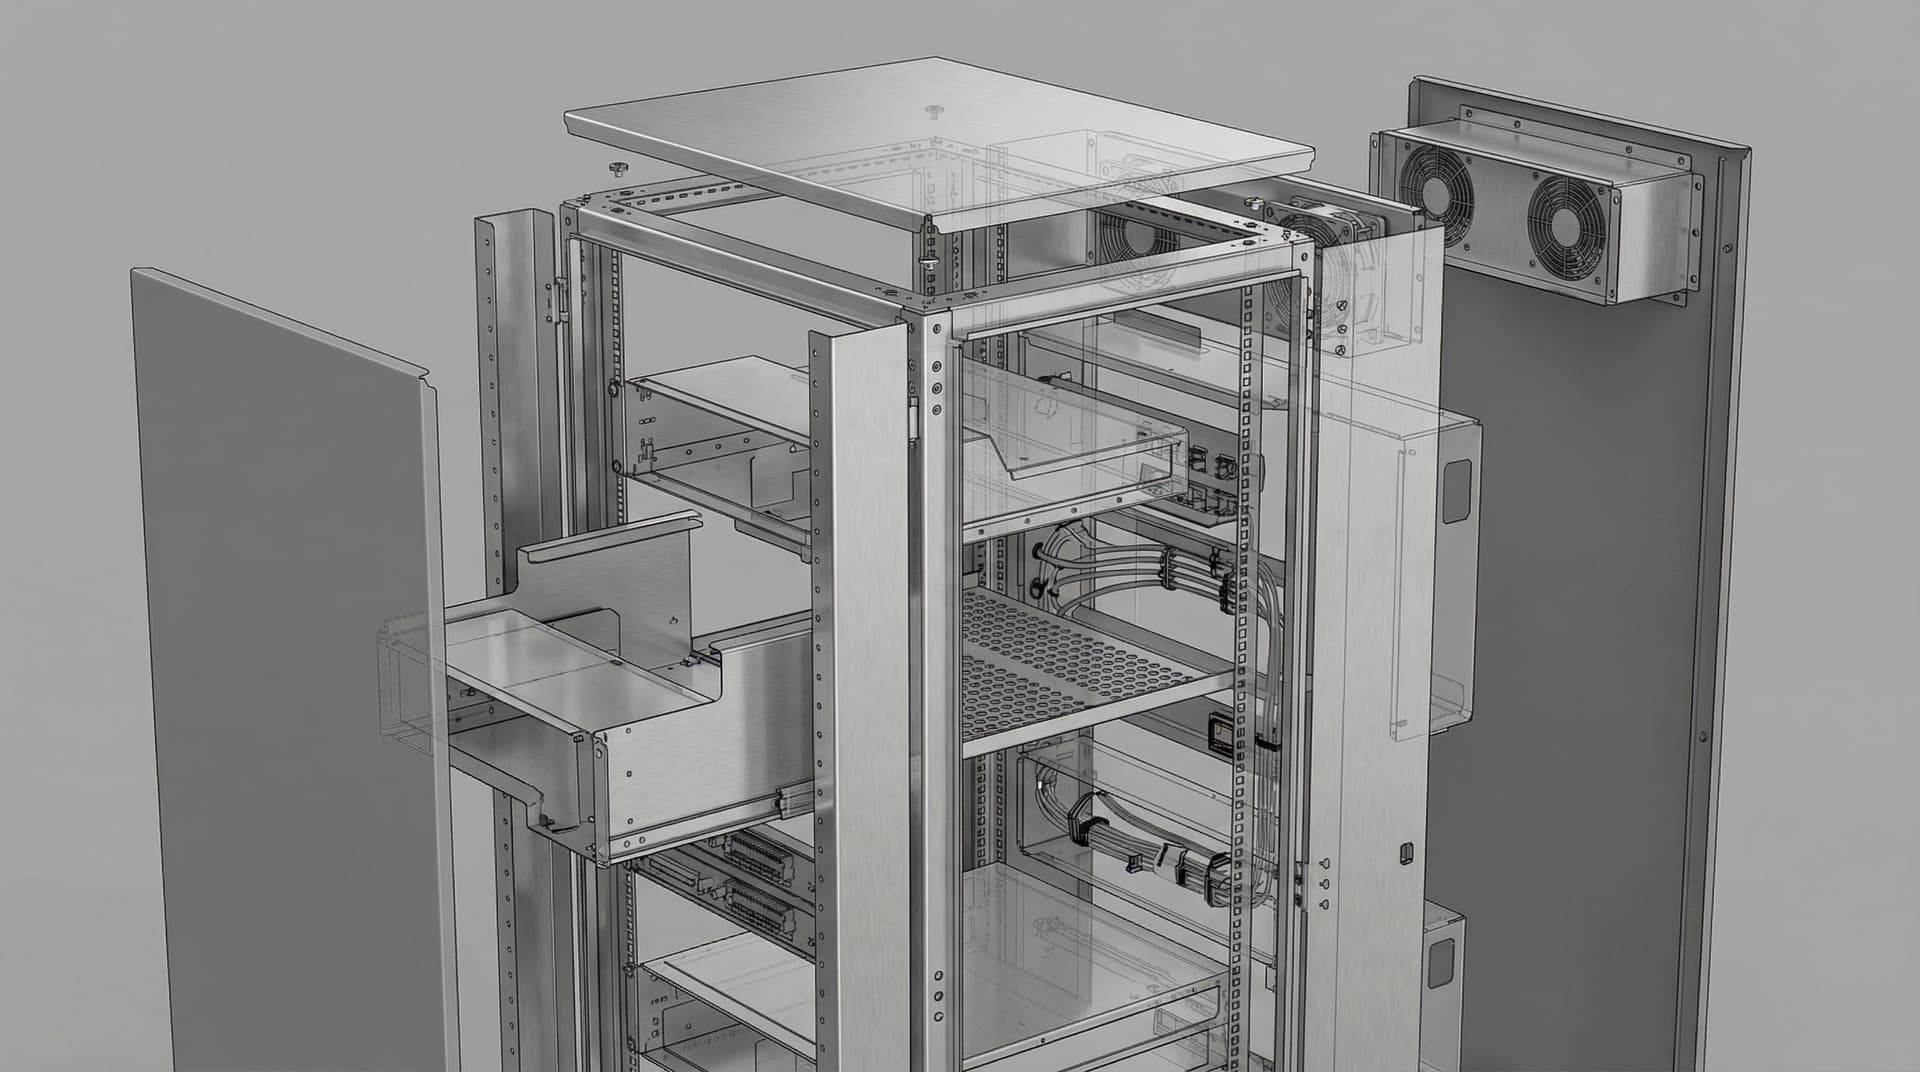
Engineering CAD study detailing the sheet metal architecture of a 45 kg industrial power inverter cabinet with calculated K-factor bend tables, PEM hardware, and flat patterns.

CFD simulation study analyzing conjugate heat transfer (CHT), hotspot dissipation, and external heat sink fin geometry for a sealed electronics enclosure operating in 45°C ambient air.

Robotics engineering study demonstrating unstructured bin-picking using YOLOv11-Seg instance segmentation, 3D surface normal extraction, and collision-free grasp trajectory planning.

Airframe engineering study using topology optimization and modal FEA to compare structural mass and predicted vibration behaviour across a CAD design iteration.

Engineering research study evaluating deep learning surrogate models to predict structural stress fields in tens of milliseconds—accelerating iterative CAD parameter sweeps.

Embedded vision study deploying quantized neural networks on a low-cost ESP32-S3 microcontroller to classify surface and assembly defects locally without PC hardware.

Computer vision study evaluating parameter-efficient fine-tuning (LoRA) on OpenCLIP for visual recognition across industrial mechanical fasteners.

Systems engineering study examining containerized model rollouts, heartbeat telemetry, and automated rollback workflows for distributed edge vision devices.

Software architecture study developing a retrieval-augmented generation (RAG) system with hybrid search and citation tracking across engineering drawings and CAD documentation.
Connect with our engineering leads to review your requirements, technical constraints, and development roadmap. NDA protection is available where required.