All case studies
Robotics & AutomationNDA-PROTECTED CLIENT PROJECT

6-DOF Teleoperated Robotic Arm Mechanical Architecture & Kinematics

For a confidential robotics client, YantriX engineered the mechanical architecture of a 6-DOF teleoperated manipulator arm—focusing on cycloidal gearbox joint stacks, structural link stiffness, bearing life sizing, and CNC machining DFM under tight envelope constraints.

By Tirth Borda · Co-Founder · Robotics Systems Lead2 min readRobotics & Teleoperation
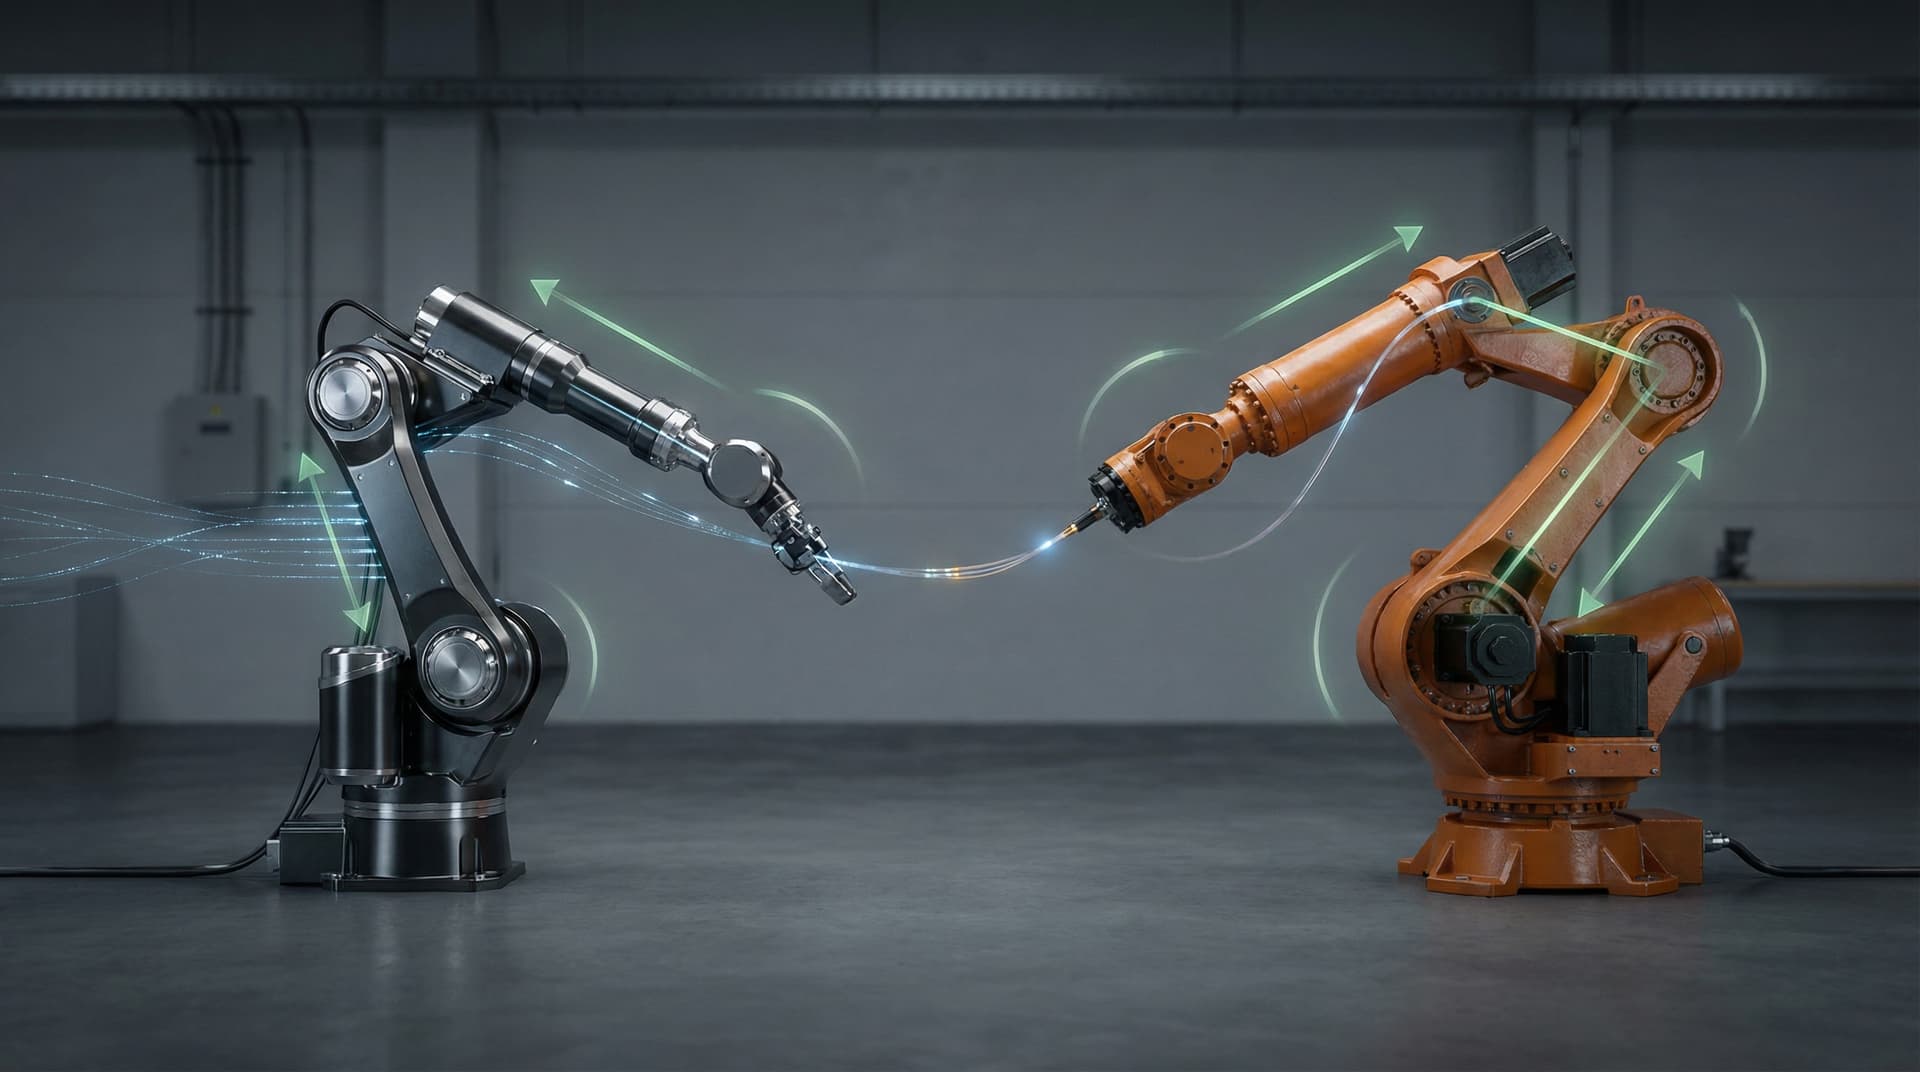
6-DOF teleoperated robotic arm mechanical design and joint stack

Overview

Engineering Scope & Context

Mechanical architecture, cycloidal joint packaging, kinematic clearance checking, and machining DFM for a compact 6-DOF teleoperated manipulator arm.

Client Confidentiality Notice

Certain geometry, component selections, and client-specific performance requirements are omitted under confidentiality.

Engagement: NDA-PROTECTED CLIENT PROJECT

Discipline: Robotics & Automation

Project Type: Robotics Engineering (Kinematics + Mechanical CAD + DFM)

Client: Confidential Robotics Client (NDA Protected)

Application: Robotics & Teleoperation

YantriX Scope Ownership

  • 6-DOF kinematic reach and joint articulation architecture
  • Cycloidal gearbox joint stack and housing mechanical packaging
  • Structural link cross-section FEA for torsional and bending stiffness
  • Bearing life calculation, seal packaging, and thermal dissipation paths
  • Detailed 3D CAD modeling in SolidWorks with manufacturing clearance analysis
  • 2D manufacturing drawing packages prepared using ASME Y14.5 GD&T practices
  • DFM review for multi-axis CNC aluminum machining and anodizing

Key specifications

Core engineering parameters & stack.

6-DOF
Kinematic Configuration (Design Specification)
920 mm
Spherical Reach Envelope (Design Specification)
5 kg
Rated Payload Capacity (Design Target)
MoveIt 2
Kinematic Trajectory Validation (Simulation)

Objectives

What the project needed to achieve

  • Package 6 articulated joint axes within an aggressive total arm weight envelope
  • Achieve a 920 mm spherical working reach volume with low backlash
  • Design cycloidal joint housings with integrated cross-roller bearing seats
  • Conduct FEA deflection analysis on upper arm and forearm links under 5 kg payload
  • Deliver production drawing packages using ASME Y14.5 GD&T practices for CNC machining

Challenge

Engineering constraint

The client required an articulated 6-DOF manipulator capable of operating in compact workstations while maintaining structural rigidity at maximum reach under a 5 kg rated payload. Off-the-shelf industrial collaborative arms were too bulky and costly for the required integration envelope. Key engineering challenges included packaging high-reduction cycloidal joint mechanisms into low-profile housing envelopes, managing torsional deflection along the forearm, and routing internal motor power and encoder wiring through hollow joint axes without mechanical pinching.

Approach

How YantriX approached the work

  1. 01

    Modeled forward and inverse kinematics to verify link lengths, joint velocity limits, and workspace reachability.

  2. 02

    Engineered modular joint stacks integrating cycloidal drive discs, eccentric shafts, dynamic seals, and absolute magnetic encoders.

  3. 03

    Conducted finite element analysis (FEA) on structural arm links in SolidWorks Simulation, iterating wall thicknesses to resist peak torque without excessive mass.

  4. 04

    Established internal wiring harness channels with protected service loops through hollow joint shafts to eliminate external snag hazards.

  5. 05

    Prepared 2D engineering drawing packages with geometric tolerancing for critical bearing fits, concentricity, and seal gland compression.

Outcomes

What improved by the end

  • Completed the 6-DOF solid-model assembly; CAD motion review indicated clearance through the modeled range of motion
  • Designed 920 mm working reach envelope with total arm mass under 19 kg
  • FEA estimated a link structural factor of safety above 2.2 under the defined full-extension static load case
  • Standardized modular joint bearing and seal interfaces to simplify assembly and maintenance
  • Released comprehensive 2D manufacturing drawing packages with GD&T for prototype machining

Deliverables

Engineering Scope & Deliverables

  • Parametric SolidWorks 3D CAD solid models and assembly files
  • Neutral STEP/IGES exchange geometry
  • 2D manufacturing drawings using ASME Y14.5 GD&T practices
  • Engineering Bill of Materials (BOM) with specified hardware and bearings
  • Assembly procedure guide and wiring routing layout documentation

Tools used

Stack and tooling

  • SolidWorks CAD
  • SolidWorks Simulation (FEA)
  • MATLAB Kinematics
  • ASME Y14.5 GD&T

Impact

Business-level effect

  • Enabled the client to proceed with prototype procurement using the prepared manufacturing drawings
  • Eliminated external cable snags through fully integrated internal joint pass-throughs
  • Provided independent CAD and drawings owned 100% by the client under agreed NDA terms

Conclusion

Articulated manipulator design succeeds when joint packaging and structural stiffness are addressed together. By treating bearing placement, cycloidal drive housing, and cable routing as unified mechanical systems, YantriX delivered an architecture ready for precision fabrication.

Working on a similar engineering problem?

Developing an articulated robotic arm, custom joint mechanism, or teleoperated manipulator? Discuss your kinematic constraints and mechanical requirements with our robotics engineering team.

Tagged

  • Robotics
  • Manipulator
  • Kinematics
  • DFM
  • ASME Y14.5
  • SolidWorks

Related case studies

Adjacent proof you can read next.

Continue exploring

Related blogs, services, and capability pages

Explore the engineering service and practical guides related to this work.

Similar Engineering Need?

Need help developing something similar?

Discuss your 6-dof teleoperated robotic arm mechanical architecture & kinematics requirements, design challenges, or target specifications with our engineering team. NDA support is available where required.