NDA-PROTECTED CLIENT PROJECT
Robotics Engineering · Kinematics & DFM
6-DOF Teleoperated Robotic Arm Mechanical Architecture
What Was Engineered
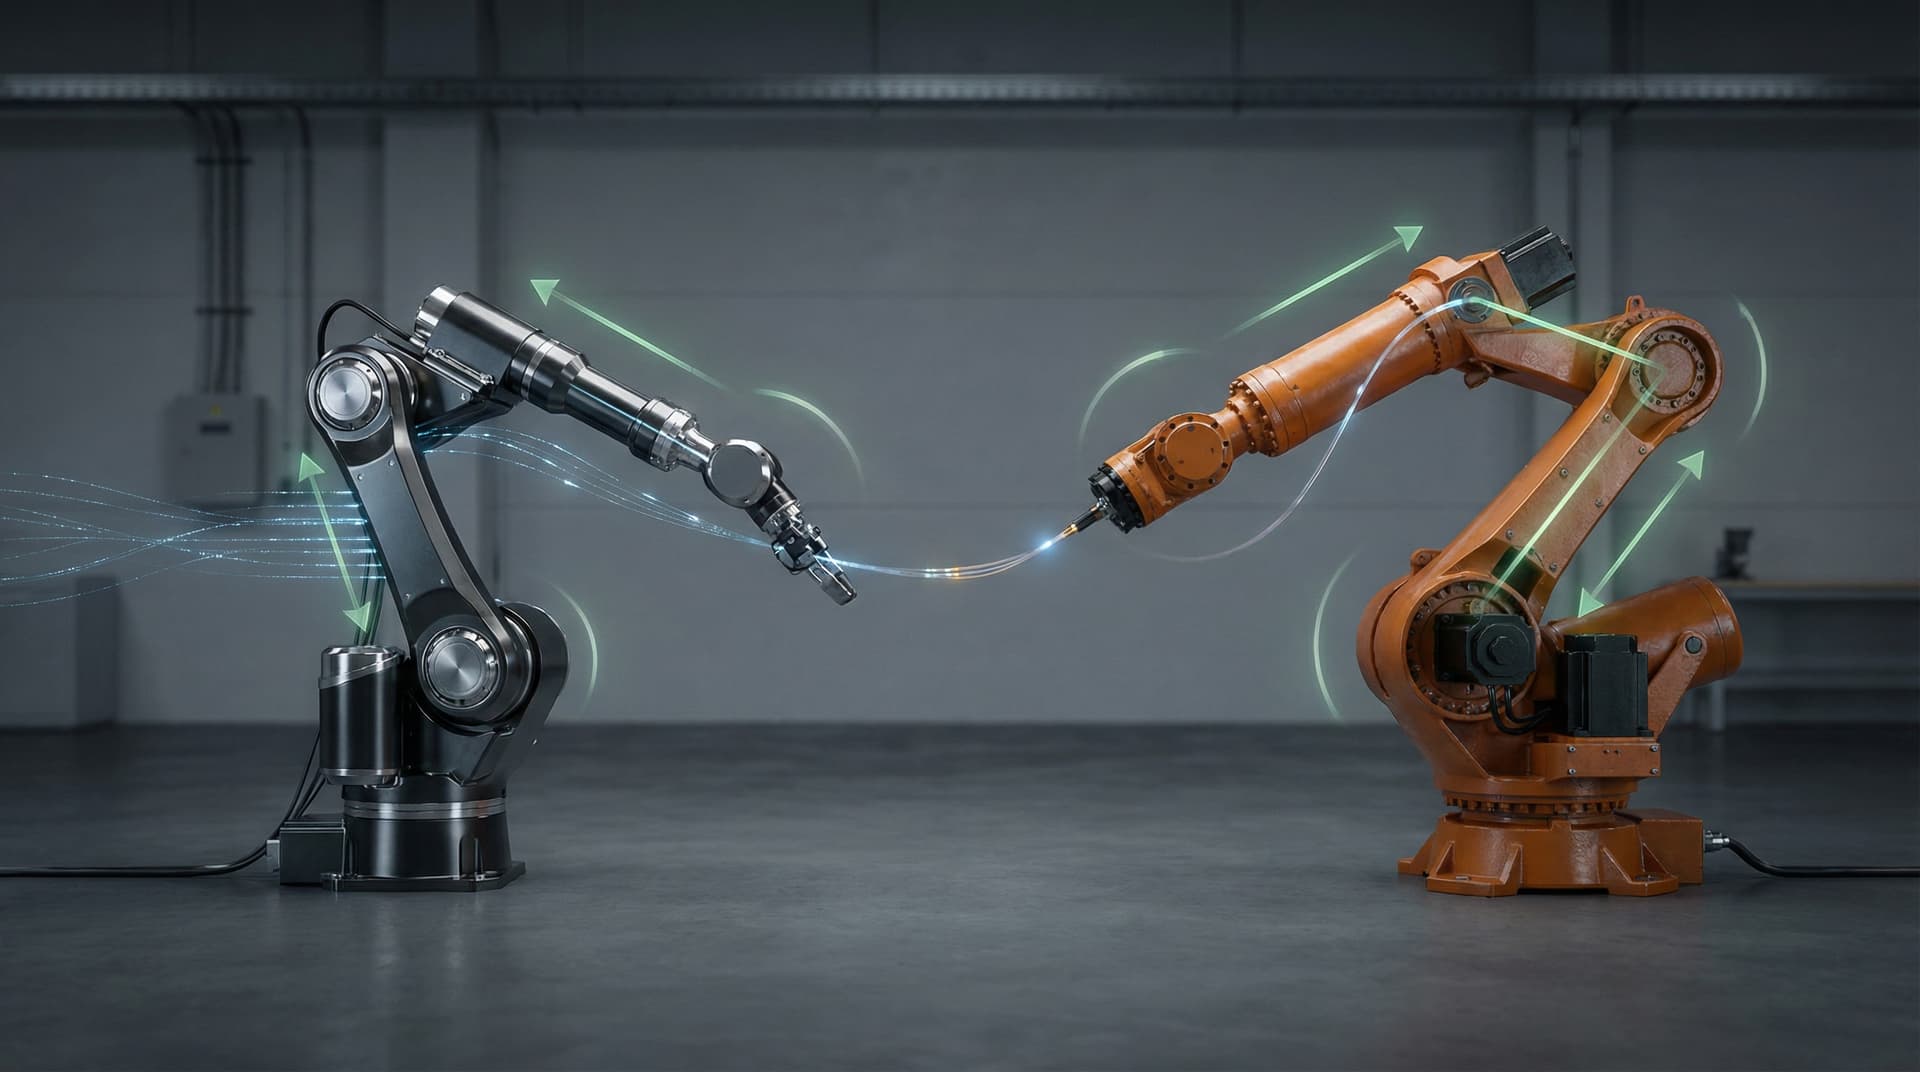
Compact 6-DOF robotic manipulator joint stacks, high-stiffness arm links, and internal routing harness.
YantriX Scope
Parametric CAD architecture in SolidWorks, cycloidal gearbox integration, FEA link stiffness, and CNC machining DFM.
Key Challenge
Targeting ±0.1 mm repeatability at 5 kg payload (design targets) in a compact joint envelope under strict target BOM.
Deliverable & Result
Production-ready CAD assembly, 2D ASME Y14.5 GD&T drawings, and fabrication package shipped for USA unit assembly.