Robotics & Automation

Robotics Engineering & Autonomous Systems

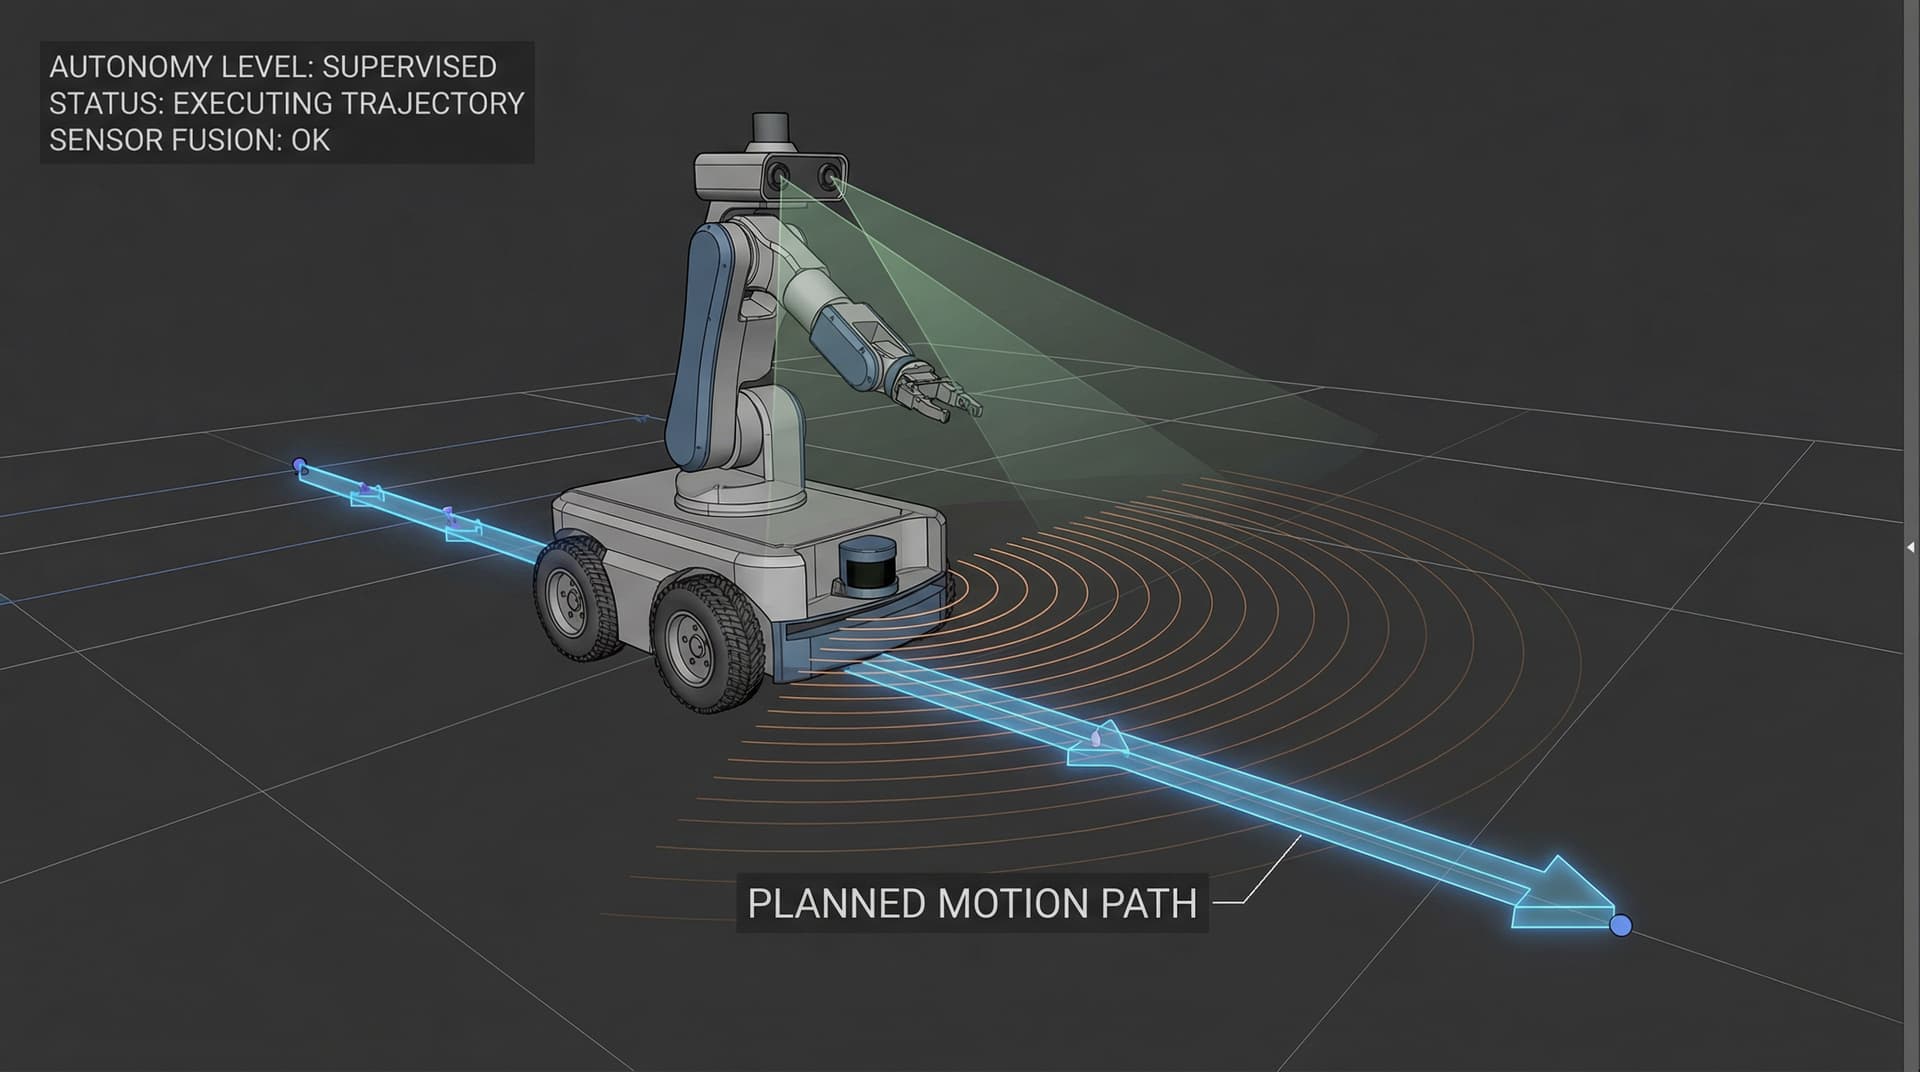
YantriX builds robotics systems that ship — from ROS 2 architecture and motion planning to the mechanical chassis and electronics that put the robot on the floor. Working from our engineering studio in India, we partner with hardware companies, research labs, and automation teams globally.

Robotics development services in India — YantriX studio working on ROS 2 mobile robot

What we do

Practical support for targeted engineering work

We deliver robotics engineering services in India across mechanical, mechatronic, embedded control, ROS 2, and perception workstreams based on project scope: ROS 2 system architecture (Humble / Jazzy), Nav2 autonomous navigation with LiDAR / visual SLAM, MoveIt arm manipulation and grasp planning, custom AGV / AMR mechanical design with skid-steer or differential drive, drive-train selection and motor sizing, ESP32 / Jetson embedded controller integration, vision-guided perception pipelines, and mechatronic integration across mechanical, electrical, and software subsystems. Engagements run from focused subsystem work (e.g. SLAM tuning on an existing platform) through ground-up custom robot programs. We deliver source code, simulation environments (Gazebo / Isaac Sim), commissioning support, and engineering documentation the client team can own.

What problems we solve

  • Reduce integration risk between mechanics, electronics, and ROS 2 software — the place where most robotics programs stall.
  • Move from concept robotics ideas to credible prototype direction with realistic timeline and budget.
  • Build custom AGVs / AMRs / robotic arms when off-the-shelf platforms don't fit the application or the budget.
  • Tune Nav2 and SLAM on existing robotics platforms for reliable autonomous navigation in real operating environments.
  • Integrate computer vision and applied AI into ROS 2 pipelines for real-time robotic perception and action.

Tools we use

  • ROS 2 Humble / Jazzy — core robotics framework
  • Nav2 — autonomous navigation stack
  • MoveIt 2 — robotic arm motion planning and manipulation
  • Gazebo, Ignition, NVIDIA Isaac Sim — simulation environments
  • Foxglove, RViz — visualization and debugging
  • NVIDIA Jetson (Nano, Orin Nano, Orin AGX) — onboard compute
  • ESP32, ESP32-S3, STM32 — embedded controllers
  • SolidWorks, Fusion 360 — mechanical chassis design
  • KiCad, Altium — custom PCB design for motor controllers and sensor breakouts
  • Intel RealSense, ZED 2i, OAK-D — depth and stereo cameras
  • Velodyne, RPLidar, Slamtec — LiDAR sensors

Deliverables

  • ROS 2 software stack with documented architecture and dependency tree
  • Mechanical chassis design — STEP files, 2D drawings, BOM, vendor recommendations
  • Embedded controller firmware (ESP32 / Jetson) with documented communication protocols
  • Custom PCB designs and fabrication packages for motor controllers, sensor breakouts, power distribution
  • Simulation environment in Gazebo / Isaac Sim for offline testing and CI
  • Commissioning support — remote or on-site — to bring the robot online
  • Engineering documentation and operator manual

Have a project requiring this engineering scope?

Share your technical requirements, 3D CAD files, or operating specs. NDA support is available where required before confidential file exchange.

Discuss Your Robotics Project
Use cases

Industries where this service applies

We adapt the same engineering service to different product contexts depending on the load case, packaging problem, validation target, or deployment environment.

Manufacturing and factory automation

Custom AMR transport platforms, robotic transfer cells, end-effector tooling, and PLC-interfaced actuation units for factory workflows.

Warehousing and logistics (AMR fleets)

High-payload chassis, shock-isolated drive wheel suspensions, LiDAR sensor towers, and automated charging dock interfaces.

Agritech (autonomous platforms for greenhouse and field)

Ruggedized outdoor chassis, IP66 spray-resistant electronic housings, solar power mounts, and terrain-adaptive suspension links.

Healthcare (lab automation and pharmacy logistics)

Automated sample vial carousel mechanisms, sterile handling end-effectors, and quiet stepper-driven linear axes.

Defense and security robotics (R&D engagements)

Rugged enclosure concepts, tracked drive assemblies, sealed slip-ring housings, and protective shell design for R&D evaluation.

Research labs and academic institutions

Open-architecture ROS 2 experimental platforms, modular sensor rigs, and custom end-effector prototypes for kinematics research.

Consumer hardware startups building robotic products

Rapid concept-to-prototype execution, bridging CAD master models, 3D printed functional iterations, and pilot manufacturing runs.

Related work

Case studies tied to this service

See how this engineering capability applies across real project scopes, analysis goals, and physical prototype iterations.

Robotics · Autonomous Mobile Robot (AMR)

Autonomous Mobile Robot (AMR) Platform Development with Nav2 & LiDAR SLAM

In-house engineering development of an 80 kg payload AMR platform—custom skid-steer steel chassis, ROS 2 Humble Nav2 autonomy, LiDAR SLAM, and embedded motor control.

Robotics · Manipulator Kinematics & DFM

6-DOF Teleoperated Robotic Arm Mechanical Architecture & Kinematics

Mechanical architecture, cycloidal joint packaging, kinematic clearance checking, and machining DFM for a compact 6-DOF teleoperated manipulator arm.

Robotics · Vision Systems & Manipulation

Vision-Guided Robotic Bin-Picking Cell with 3D Pose Estimation

Robotics engineering study demonstrating unstructured bin-picking using YOLOv11-Seg instance segmentation, 3D surface normal extraction, and collision-free grasp trajectory planning.

From the blog

Articles that support this service topic

Explore practical guides covering robotics development, perception, mechanical integration and prototyping.

Robotics

ROS 2 Mobile Robot Hardware Architecture: Microcontroller Bridging, Motor Drivers, and Sensor Integration

A technical architecture guide for engineers building AGVs and AMRs: separating real-time motor control loops on microcontrollers from high-level Nav2 autonomy on SBCs.

Robotics

AGV / AMR Design and Development in India: Heavy Payload Mobile Robots

How to design, build, and deploy AGVs and AMRs in India — drive-train selection, mechanical chassis, ROS 2 navigation, LiDAR SLAM, and the cost / timeline reality for custom mobile robot programs.

Robotics

ROS 2 Development Services in India: 2026 Practical Guide

A practical 2026 guide to sourcing ROS 2 development services in India — what's available, project shape, realistic costs, and how to evaluate Indian robotics vendors.

FAQ

Questions teams ask before they engage

Common questions teams ask before starting a project.

What robotics development services does YantriX provide?

Robotics development spanning mechanical design, mechatronics, ROS 2 system architecture, Nav2 navigation, MoveIt manipulation, AGV / AMR design, robotic arm design, ESP32 / Jetson embedded firmware, computer vision integration, and Gazebo / Isaac Sim simulation environments. We engage on multi-disciplinary robotics programs or focused subsystem work depending on client needs.

Can you build a custom AGV or AMR for our facility?

Yes — custom AMR / AGV builds are a recurring project type. We've delivered 80 kg payload AMRs with skid-steer drive, Nav2 navigation, and LiDAR SLAM. Scope includes mechanical chassis, drive-train, embedded electronics, ROS 2 software, and commissioning support.

Do you work with existing robotics platforms or only ground-up builds?

Both. Many engagements involve tuning, extending, or integrating with existing platforms — Universal Robots arms, Clearpath platforms, and custom client hardware. Subsystem work (SLAM tuning, perception integration, MoveIt configuration) is just as common as ground-up builds.

How much does robotics development cost in India?

Scope-dependent: Subsystem work (e.g. SLAM tuning, perception pipeline integration) typically runs ₹4-12 lakh. Custom AMR programs land in the ₹15-50 lakh range depending on complexity and payload. Robotic arm design programs (mechanical + ROS 2) typically ₹8-25 lakh. We quote fixed-scope projects after technical scoping.

What ROS 2 versions do you work with?

Primarily ROS 2 Humble (LTS) for production deployments and ROS 2 Jazzy (current LTS) for new programs. We can also support ROS 1 Noetic for legacy systems with recommended migration paths.

Do you support remote commissioning?

Remote commissioning and integration support can be coordinated where included in project scope. On-site requirements can be discussed individually based on the project and location.

Can you sign NDA for confidential robotics work?

Yes. An NDA can be coordinated before confidential CAD/IP exchange where required. We can review your template or provide ours upon request.

Start your project

Planning a Robotics Project? Discuss Your Robotics Project

Tell us about your kinematics, payload, ROS 2 requirements, or autonomous navigation targets to start scoping your robotics build.